Coupled estimation and control for mobile robots
What happens when a robot’s model is incomplete and its sensors can’t be fully trusted, both at the same time?
In our latest paper, we tackle both challenges simultaneously, with our doctoral researcher Amos Alwala carrying out the core research in collaboration with Dr. Gabriel Lima and Prof. Wallace Moreira Bessa.
Most mobile robot control designs deal with only one of these problems. Robust and adaptive controllers deal with unmodeled dynamics like friction, wheel slip, and changes in floor surface, but they usually assume the state estimate is reliable. Sensor fusion work improves the estimate but often pairs it with a nominal controller. Real robots face both problems at once.
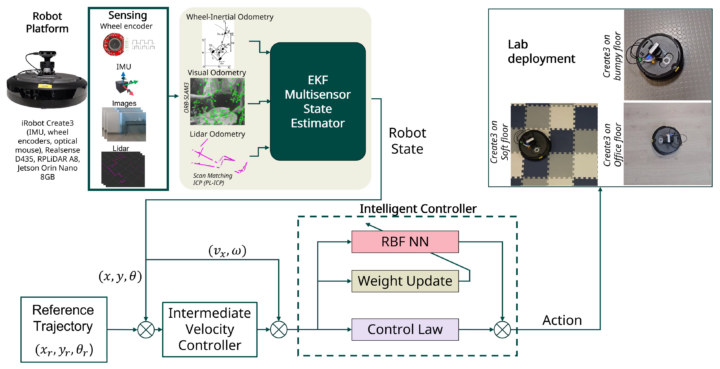
Our proposed method addresses both problems jointly on a differential-drive robot:
- An EKF fuses wheel odometry, IMU, 2D LiDAR odometry, and monocular visual odometry, so the estimate holds up when one source drifts or drops out.
- That fused estimate drives a feedback-linearization controller with an online RBF neural network, which learns the unmodeled dynamics in real time. No offline training is needed, and a Lyapunov analysis backs the stability.
- Tests on regular, soft, and bumpy floors, both in Gazebo and on an iRobot Create 3. The full pipeline runs in real time on a Jetson Orin Nano.
This work was carried out within the scope of the UTU-GreDiT: Solutions for Green and Digital Transition, Digital Waters Flagship, Digital Waters Phd Pilot and IWM Doctoral Program.
Read the full article here: [DOI]